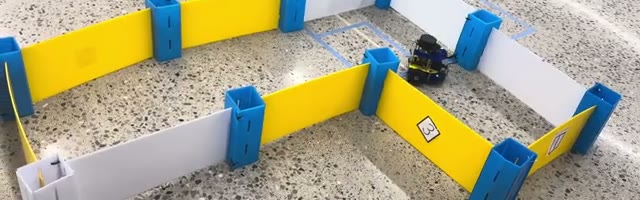
ROB 330 Fall 2026 at The University of Michigan
Development of full-stack autonomous navigation and mapping for mobile robots. Topics include dead reckoning from odometry, sensor modeling of LIDAR and cameras, visual odometry, path planning, and simultaneous localization and mapping (SLAM). Course topics will be implemented in hardware.
Course staff
Instructor
Graduate Student Instructor
Avantika Rattan
Graduate Student Instructor
Instructional Assistants
Ashrith "Ash" Edukulla
Instructional Assistant
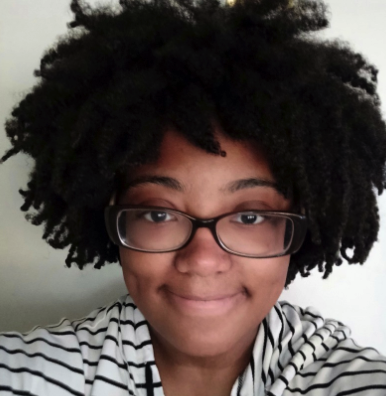
Bailey Norwood
Instructional Assistant
Support
Office hours
Cancellations and one-off changes appear here first. Times are shown in Eastern Time (Ann Arbor).
Calendar not loading? Open it in a new tab or subscribe via iCal.
See the office hours page for the recurring schedule by staff member, room and Zoom details, and how to subscribe to this calendar.